Description
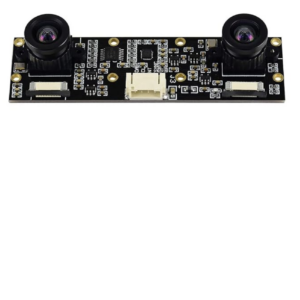
Binocular Stereo Vision Camera Module
The Binocular Stereo Vision Camera Module is designed for applications that require depth perception, 3D scene understanding, object localisation, and spatial awareness. By using two synchronised camera sensors, the module can estimate depth through stereo disparity, making it useful for robotics, autonomous systems, computer vision, and embedded AI projects.
Compared with a standard monocular camera, a stereo vision module provides additional spatial information by observing the same scene from two slightly different viewpoints. This enables software to estimate object distance, reconstruct depth maps, and improve navigation or obstacle-detection capabilities.
Key capabilities typically include:
- dual-camera stereo vision
- depth and distance estimation
- 3D scene reconstruction
- object localisation
- obstacle detection
- support for computer-vision development
- suitability for robotics and autonomous systems
- integration with embedded platforms and development computers
- compatibility with stereo-matching and depth-processing algorithms
Typical applications include:
- autonomous robots
- drone navigation
- obstacle avoidance
- robotic perception
- SLAM
- depth mapping
- 3D reconstruction
- object tracking
- machine vision
- research and education
- embedded AI systems
The module is particularly useful for developers working with platforms such as NVIDIA Jetson, Raspberry Pi, ROS2, OpenCV, and custom computer-vision pipelines.
Actual performance, frame rate, interface type, resolution, field of view, and supported depth range depend on the specific camera module, so these specifications should be checked against the manufacturer’s product listing before purchase.
Reviews
There are no reviews yet.